
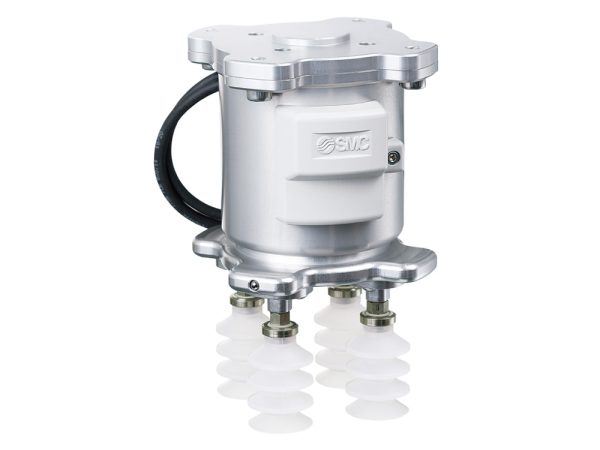

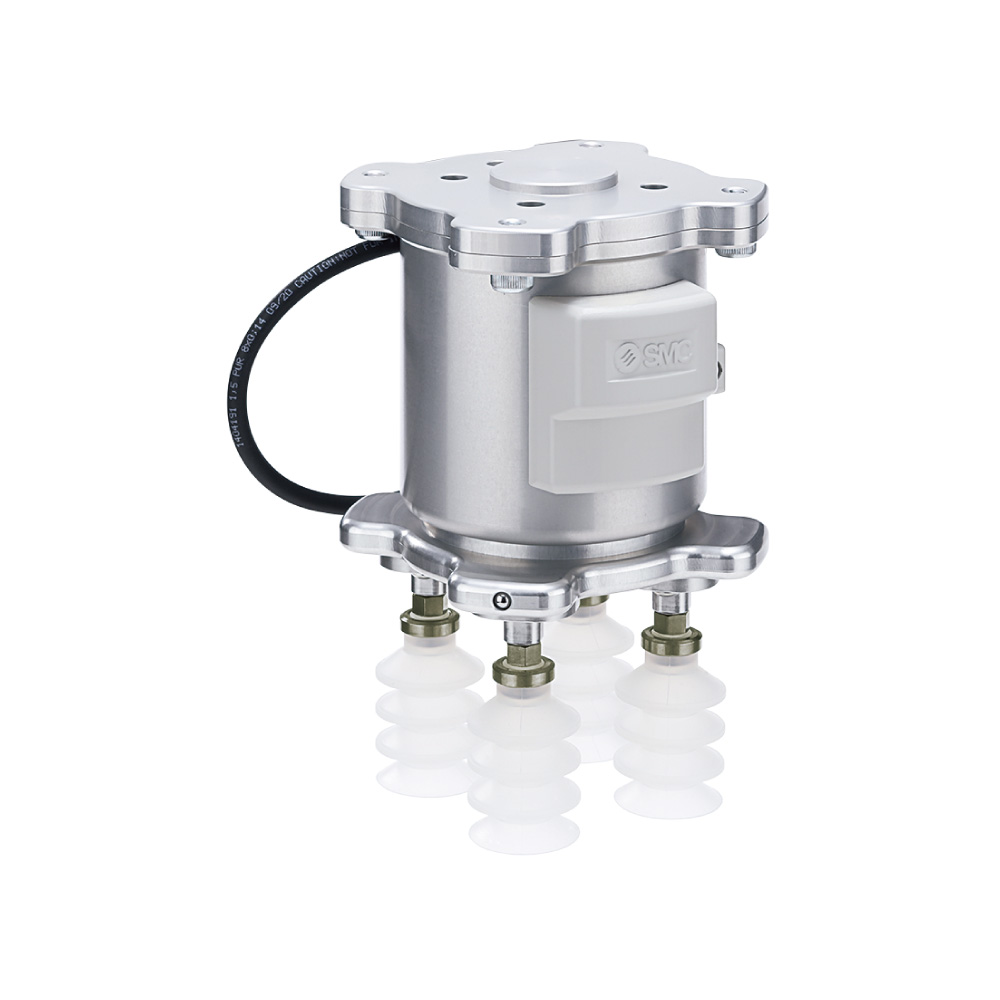
■Vacuum Gripper for Collaborative Robots
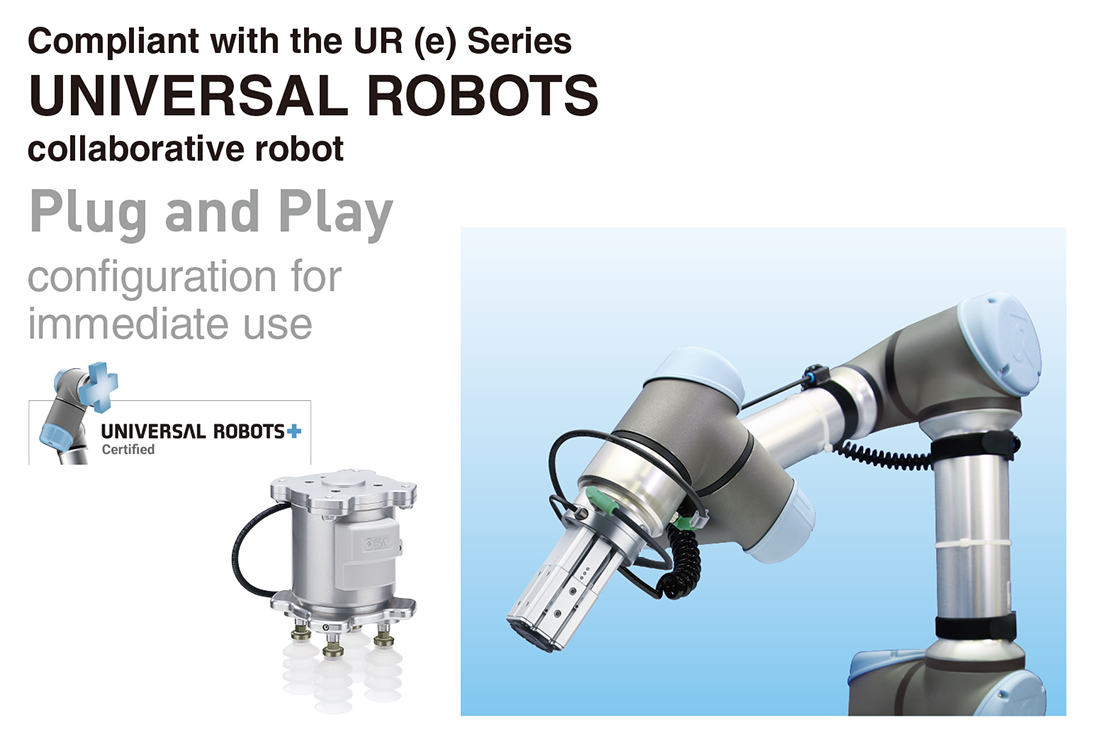
■Operate by simply connecting 1 compressed air supply tube and an electrical wiring M8 connector.
■Integrated vacuum ejector, air supply valve, pressure switch, and cups
■Standards: Conforming to ISO9409-1-50-4-M6
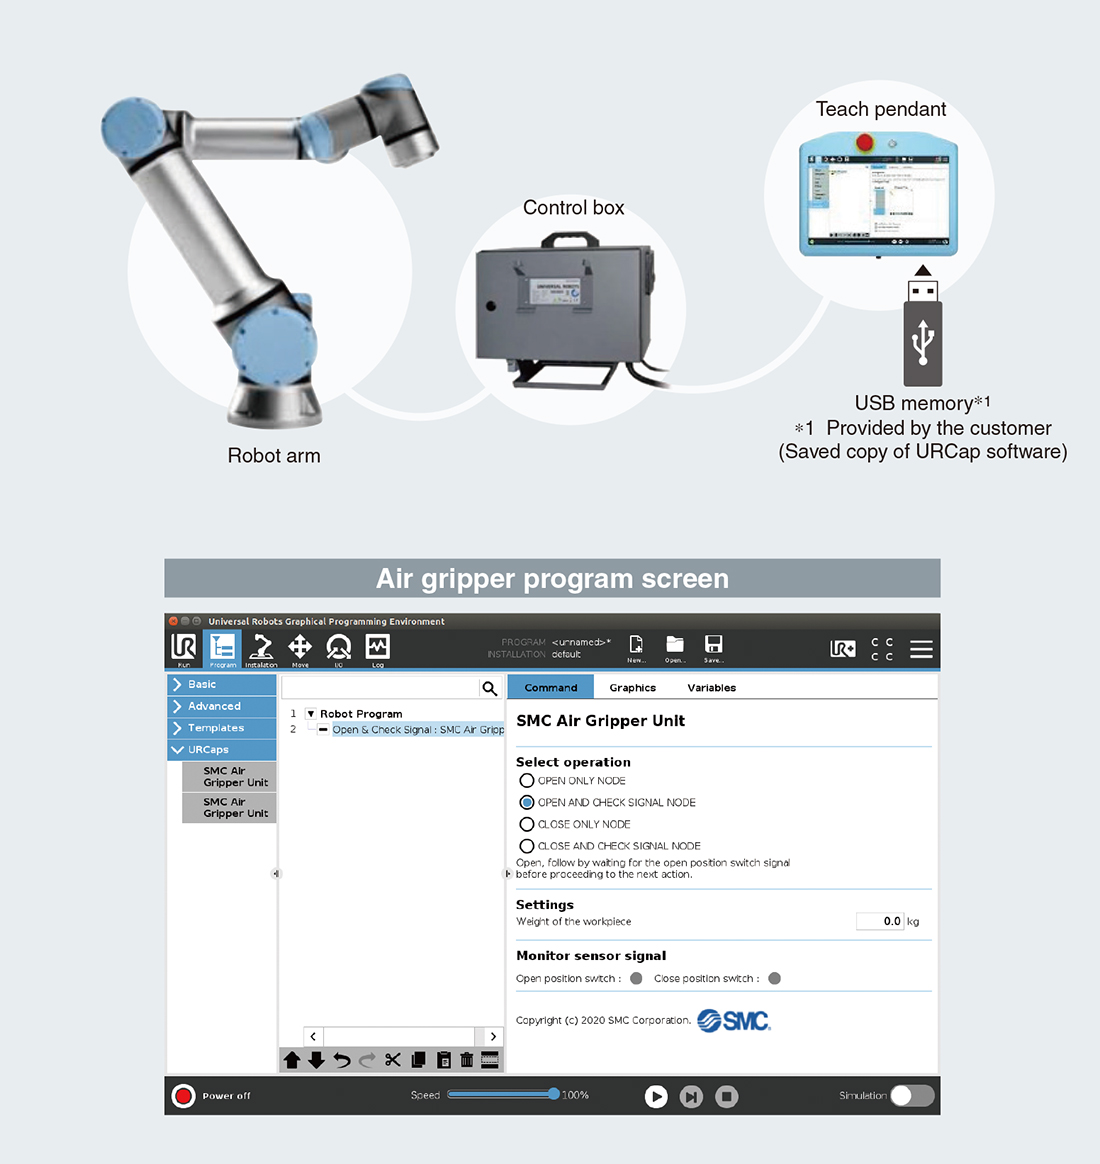
■URCap
■Specifications
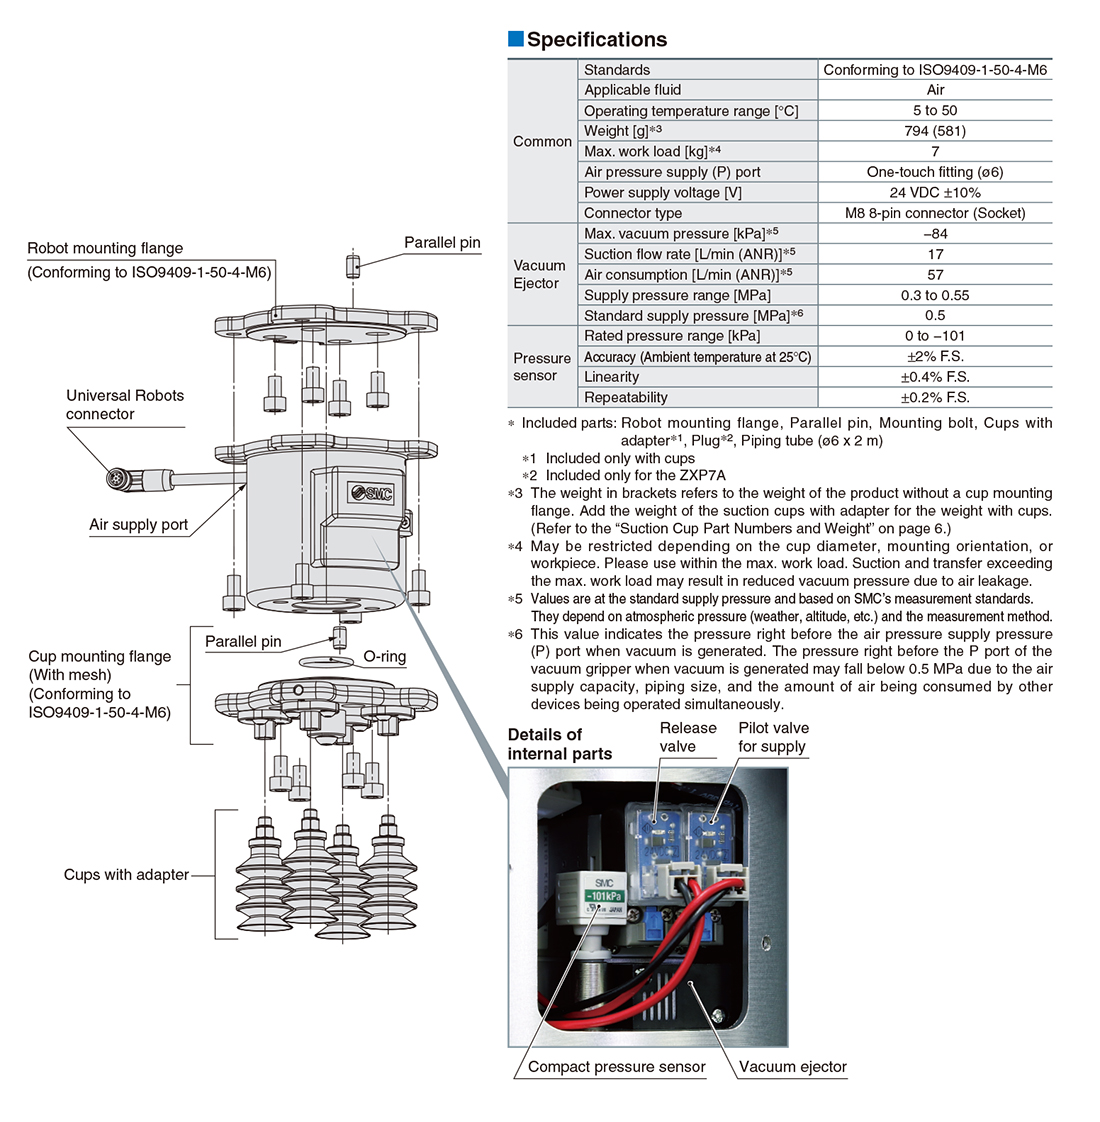
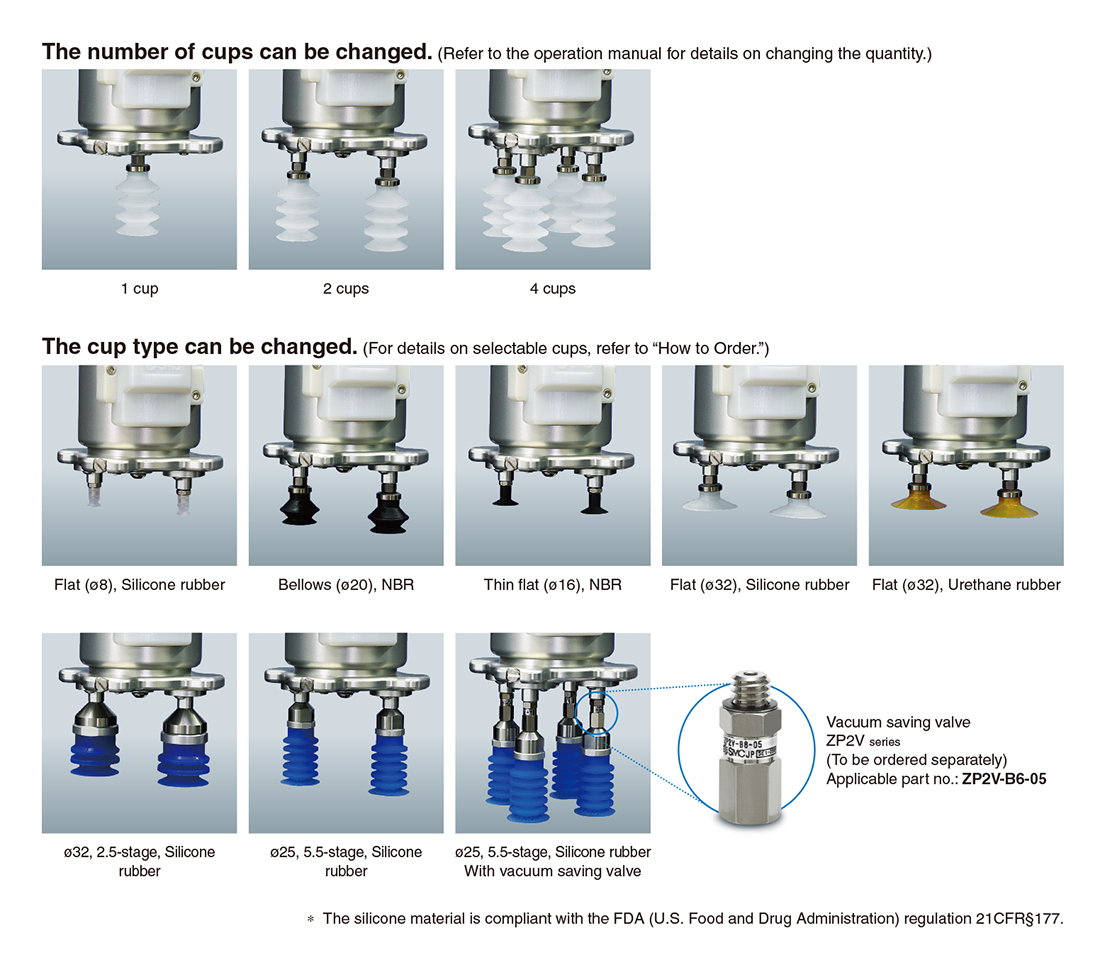
■Cup Variations
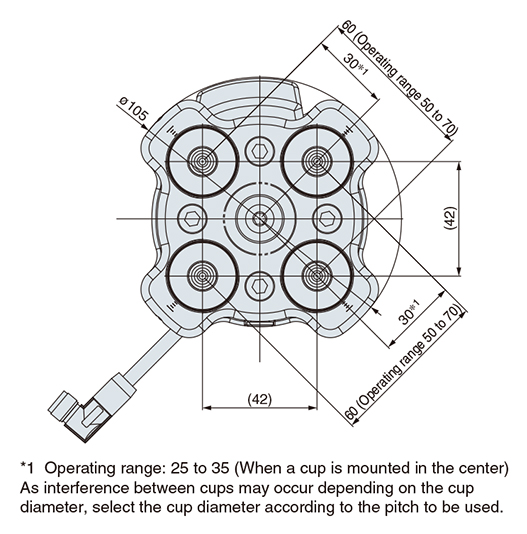
■The cup pitch can be changed.
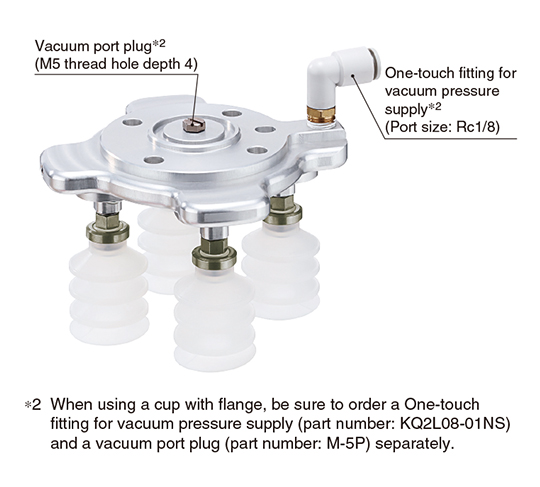
■The cup with flange can be used separately
(if using an external vacuum source).
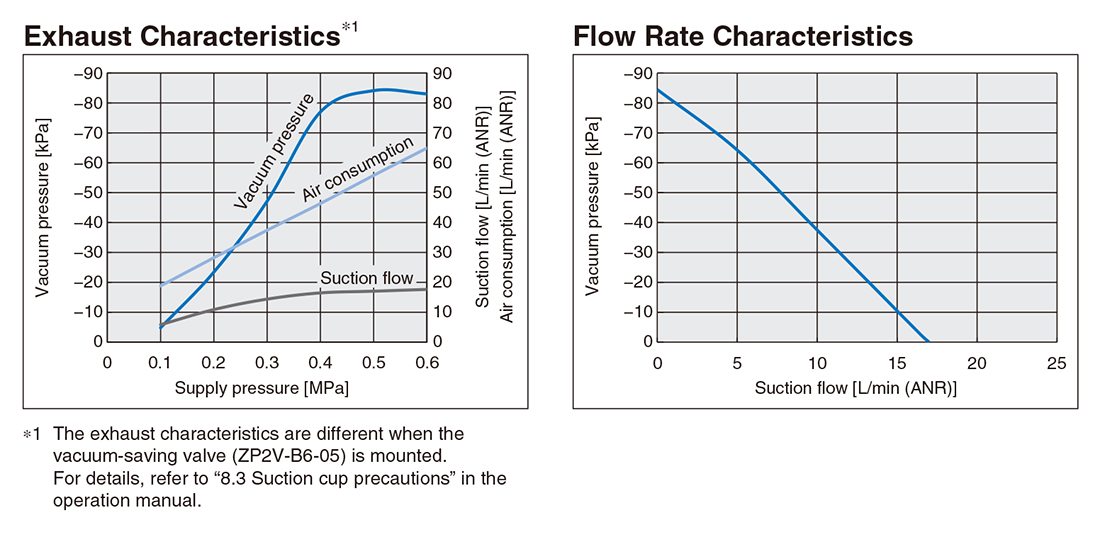
■Model Selection
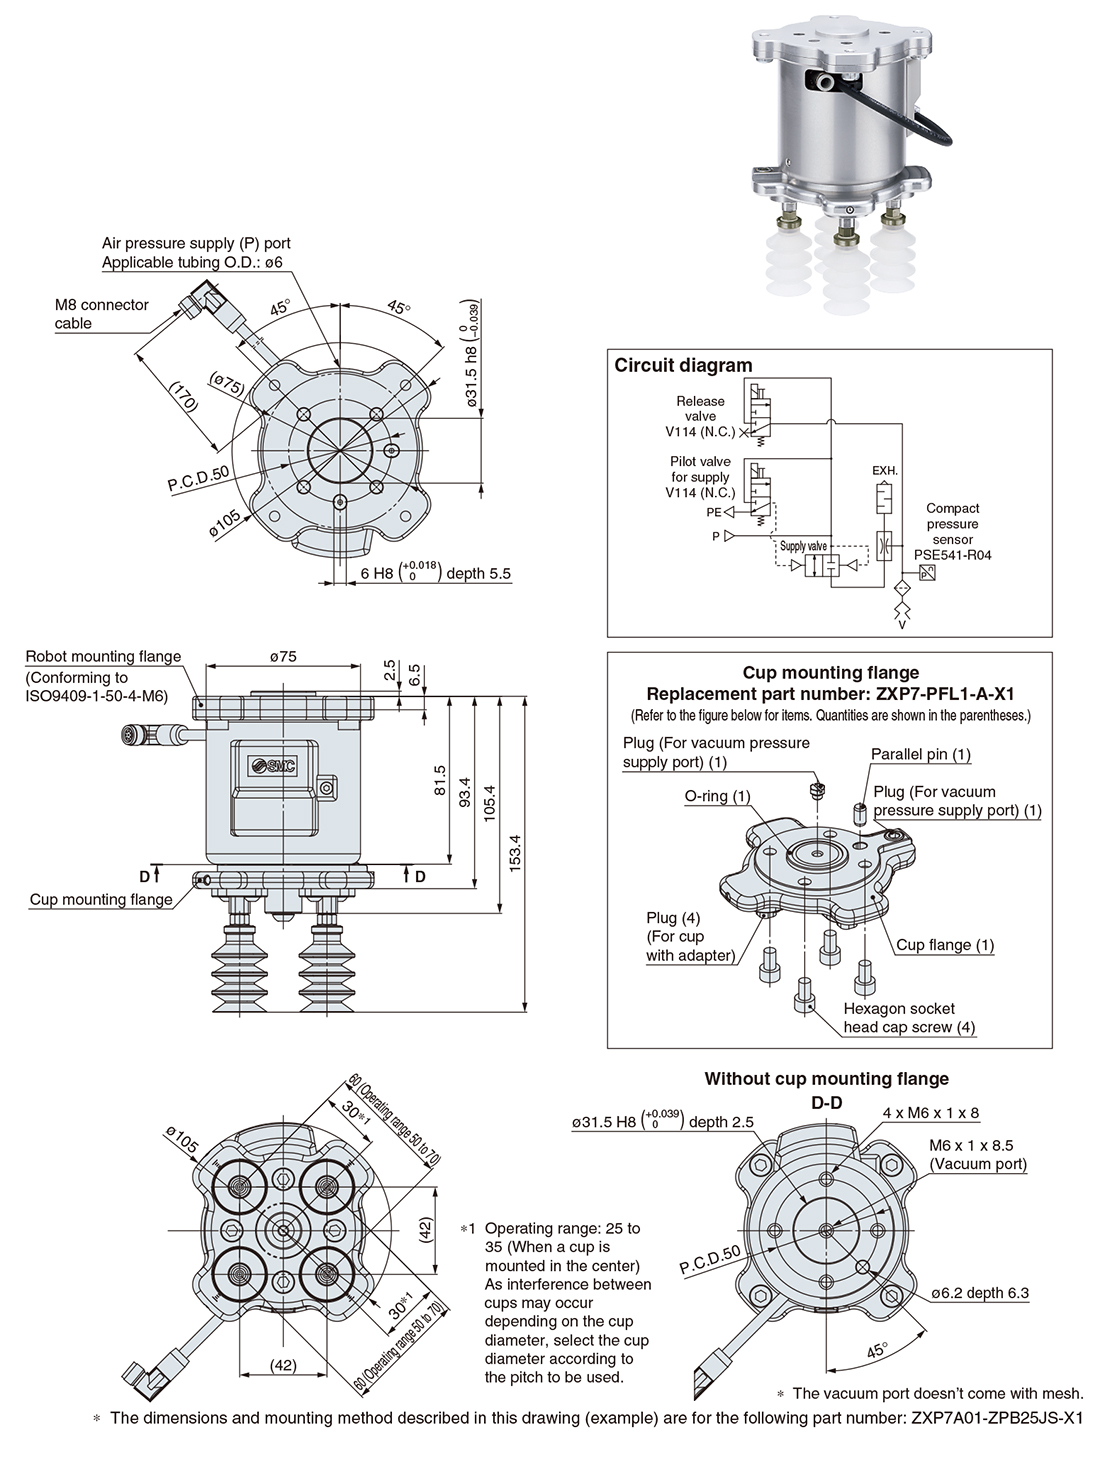
■Dimensions
■URCap
Easy programming
By using the dedicated software certified for Universal Robots, URCap, the teaching pendant can conduct various operations of SMC grippers intuitively, allowing for sensor signals to be easily incorporated.
Save a copy of the URCap software to a USB memory and insert it into the teaching pendant to easily install the software.
* Please download the URCap software from the website, and save it to a USB memory.
Reviews
There are no reviews yet.